Servo — channel initialization (servo_init)
What it does: Initializes the selected servo channel (servo1 to servo8) on the given pin and optionally reverses the direction.
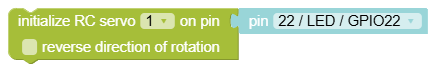
Inputs
- Field
ID: servo channel number (1to8). pin: GPIO pin number for servo signal.- Field
reverse direction of rotation: direction reversal option (True/False).
Output
- None (statement block).
When to use it
- At the beginning of the program before all blocks
servo_angle,set_servo_speed,set_servo_us. - When you use multiple servers at the same time and want to separate them by ID.
Tips and pitfalls
- When using drives, also use a block to stop them when you press the STOP button in ESP IDE. Block: Execute this code on program exit
- Power the servo with a separate source. 3.3V is used to power the processor, not as a power supply voltage for motors and servos. The GPIO pin serves only as a control signal.
reverse direction of rotationis useful when the servo is mechanically mounted in reverse, or we use two servos mirrored next to each other.
Usage example
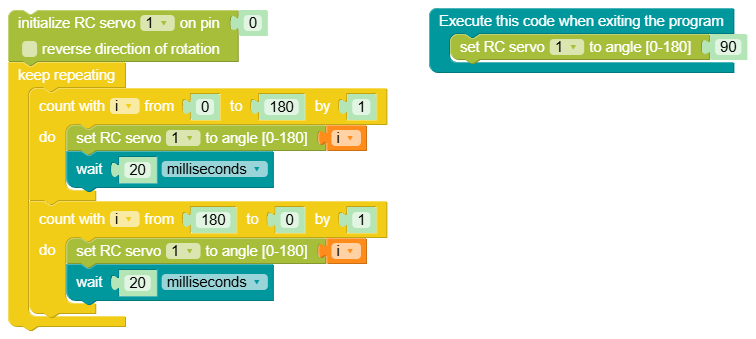
Generated Python example
servo1 = Servo(Pin(18), reverse=True)