Servo 360° — set speed -100 to 100 (set_servo_speed)
What it does: Sets the speed and direction of a continuous (360°) servo.
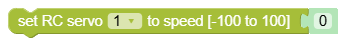
Inputs
- Field
ID: servo channel number (1to8). speed: speed-100to100(0means stop).
Output
- None (statement block).
When to use it
- For continuous and positioning servos controlled by a value in percentages -100% to 100%.
- For carriages, feeders or simple drives controlled by joystick or ESP NOW RC.
Tips and pitfalls
- When using drives, also use a block to stop them when you press the STOP button in ESP IDE. Block: Execute this code on program exit
- This block can also be used for classic position servos that we want to control with a joystick or with ESP NOW RC in the range -100% to 100%.
- The direction of rotation depends on the connection and possibly the
reverse direction of rotationsetting during initialization.
Usage example
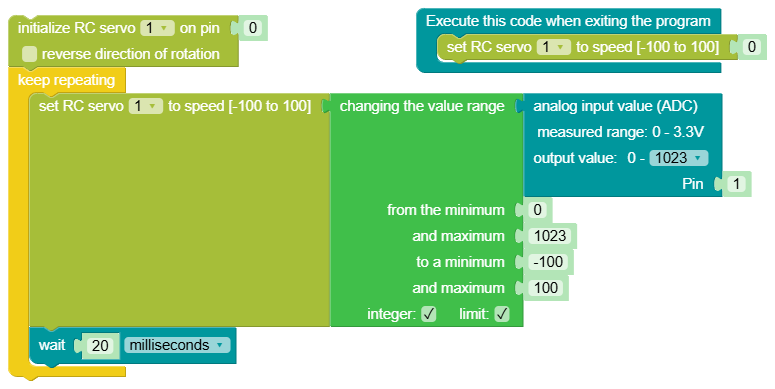
Generated Python example
servo1.write_speed(int(40))