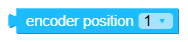
Rotary encoder — current position (encoder_get)
What it does: Returns the current position of the encoder already recalculated according to the set scale.
Inputs
- Field
index: encoder instance selection.
Output
- Number: current position of the selected encoder.
When to use it
- When reading user input from a rotary controller.
- For incremental control of values (brightness, volume, setpoint).
Tips and pitfalls
- The position is a shared value changed in an interrupt, therefore it is read atomically in the implementation.
- At high rotation speed, it may be necessary to adjust the mechanics or filtration.
Usage example
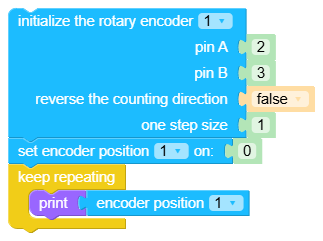
Generated Python example
value = encoder1.position